
Scouts and mappers
Long span, high aspect ratio, INAV or ArduPilot in the bay. They fly waypoints, take overlapping photographs, and come home on a lost-link script. Endurance is the weapon.
Home / Types
Dossier 04 / Wing and rotor
One motor, a wing or a main rotor, and the older virtues of aviation: cruise, glide, and hours on station. These machines look more like aeroplanes because they are aeroplanes.
A fixed-wing UAV makes lift by moving forward. Once it is at flying speed, the motor only has to beat drag. That is why a foam scout the size of a model can cross a parish on a pack that would give a 5-inch quad ten minutes. The wartime parallel is exact: a Wellington stayed up because the wing did the holding, not the engines.
Most small scouts are pushers. The prop sits behind the wing so the nose stays clear for a camera, just as a photo-recce Mosquito kept glass in front and merlins out on the wings. Puller layouts exist where cooling and simplicity matter more than a clean lens.
There is a stall. There is a takeoff run, or a hand launch, or a catapult. Landing is a flare onto grass or a belly skid, unless the airframe is a VTOL hybrid with extra lift motors. Students who only know quads are often caught out by this: the sticks no longer mean “go there.” They mean “set attitude and energy,” the same as a Chipmunk.
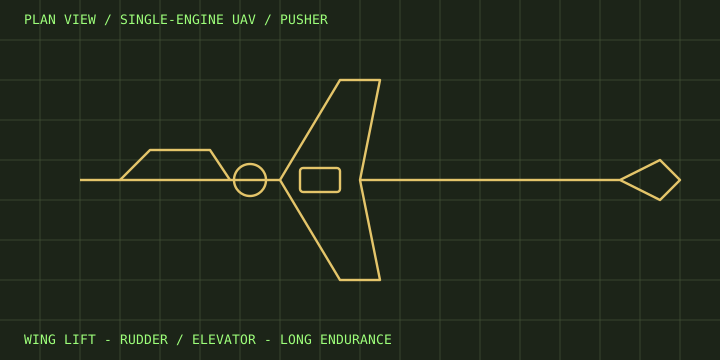
Long span, high aspect ratio, INAV or ArduPilot in the bay. They fly waypoints, take overlapping photographs, and come home on a lost-link script. Endurance is the weapon.
One main rotor and a tail rotor, or a coaxial pair. Better hover efficiency than a quad, harder to tune, useful when you need lift and a small footprint. The swashplate is back.
Lift motors for the airfield, a pusher for the cruise. You pay in weight and complexity and gain a scout that does not need a strip. Tailsitters are the other answer: the whole airframe stands on its prop, then pitches over.
Elevator sets pitch. Ailerons (or spoilers, or wing warping on some foam) set roll. Rudder coordinates. The flight controller still runs a loop, but it is trimming an aeroplane, not balancing four hover discs. Autopilots such as PX4 and ArduPlane speak the language of airspeed, altitude hold, and loiter – instrument flying, not stick fighting.
Radio and video work the same way they do on a quad, with one practical difference: the aircraft may be a dot when you need to recover it. A good compass, a return-to-home path, and a video link that still paints the horizon matter more than peak roll rate.
If you want the opposite machine – hover, gates, and a cockpit that never looks at the ground from outside – read how FPV drones work.